Sheng WANG
Ph.D. from The Hong Kong University of Science and Technology
This is an optimistic pessimist.
Email: swangei[at]connect.ust.hk
Hi, I’m Sheng Wang. I currently lead the World Model Group at RoboScience, where I focus on embodied AI and world models. My team is actively hiring full-time researchers and interns — if you are excited about embodied AI and world models, I would love to collaborate, so feel free to reach out.
I earned my Ph.D. from the Hong Kong University of Science and Technology (HKUST), where I was fortunate to be supervised by Prof. Pedro V. SANDER and Prof. Junwei LIANG. During my Ph.D., my research centered on vision-language-action (VLA) and end-to-end learning for autonomous driving. I had an unforgettable time at the Cheng Kar-Shun Robotics Institute (CKSRI) and the Intelligent and Autonomous Driving Center (IADC), where I learned a great deal and enjoyed working alongside my colleagues.
Before joining HKUST, I completed my Master’s degree in Advanced Robotics at École Centrale de Nantes (ECN), France, in 2020, and my Bachelor’s degree in Optoelectronic Information Science and Engineering at Harbin Institute of Technology (HIT), China, in 2018.
News
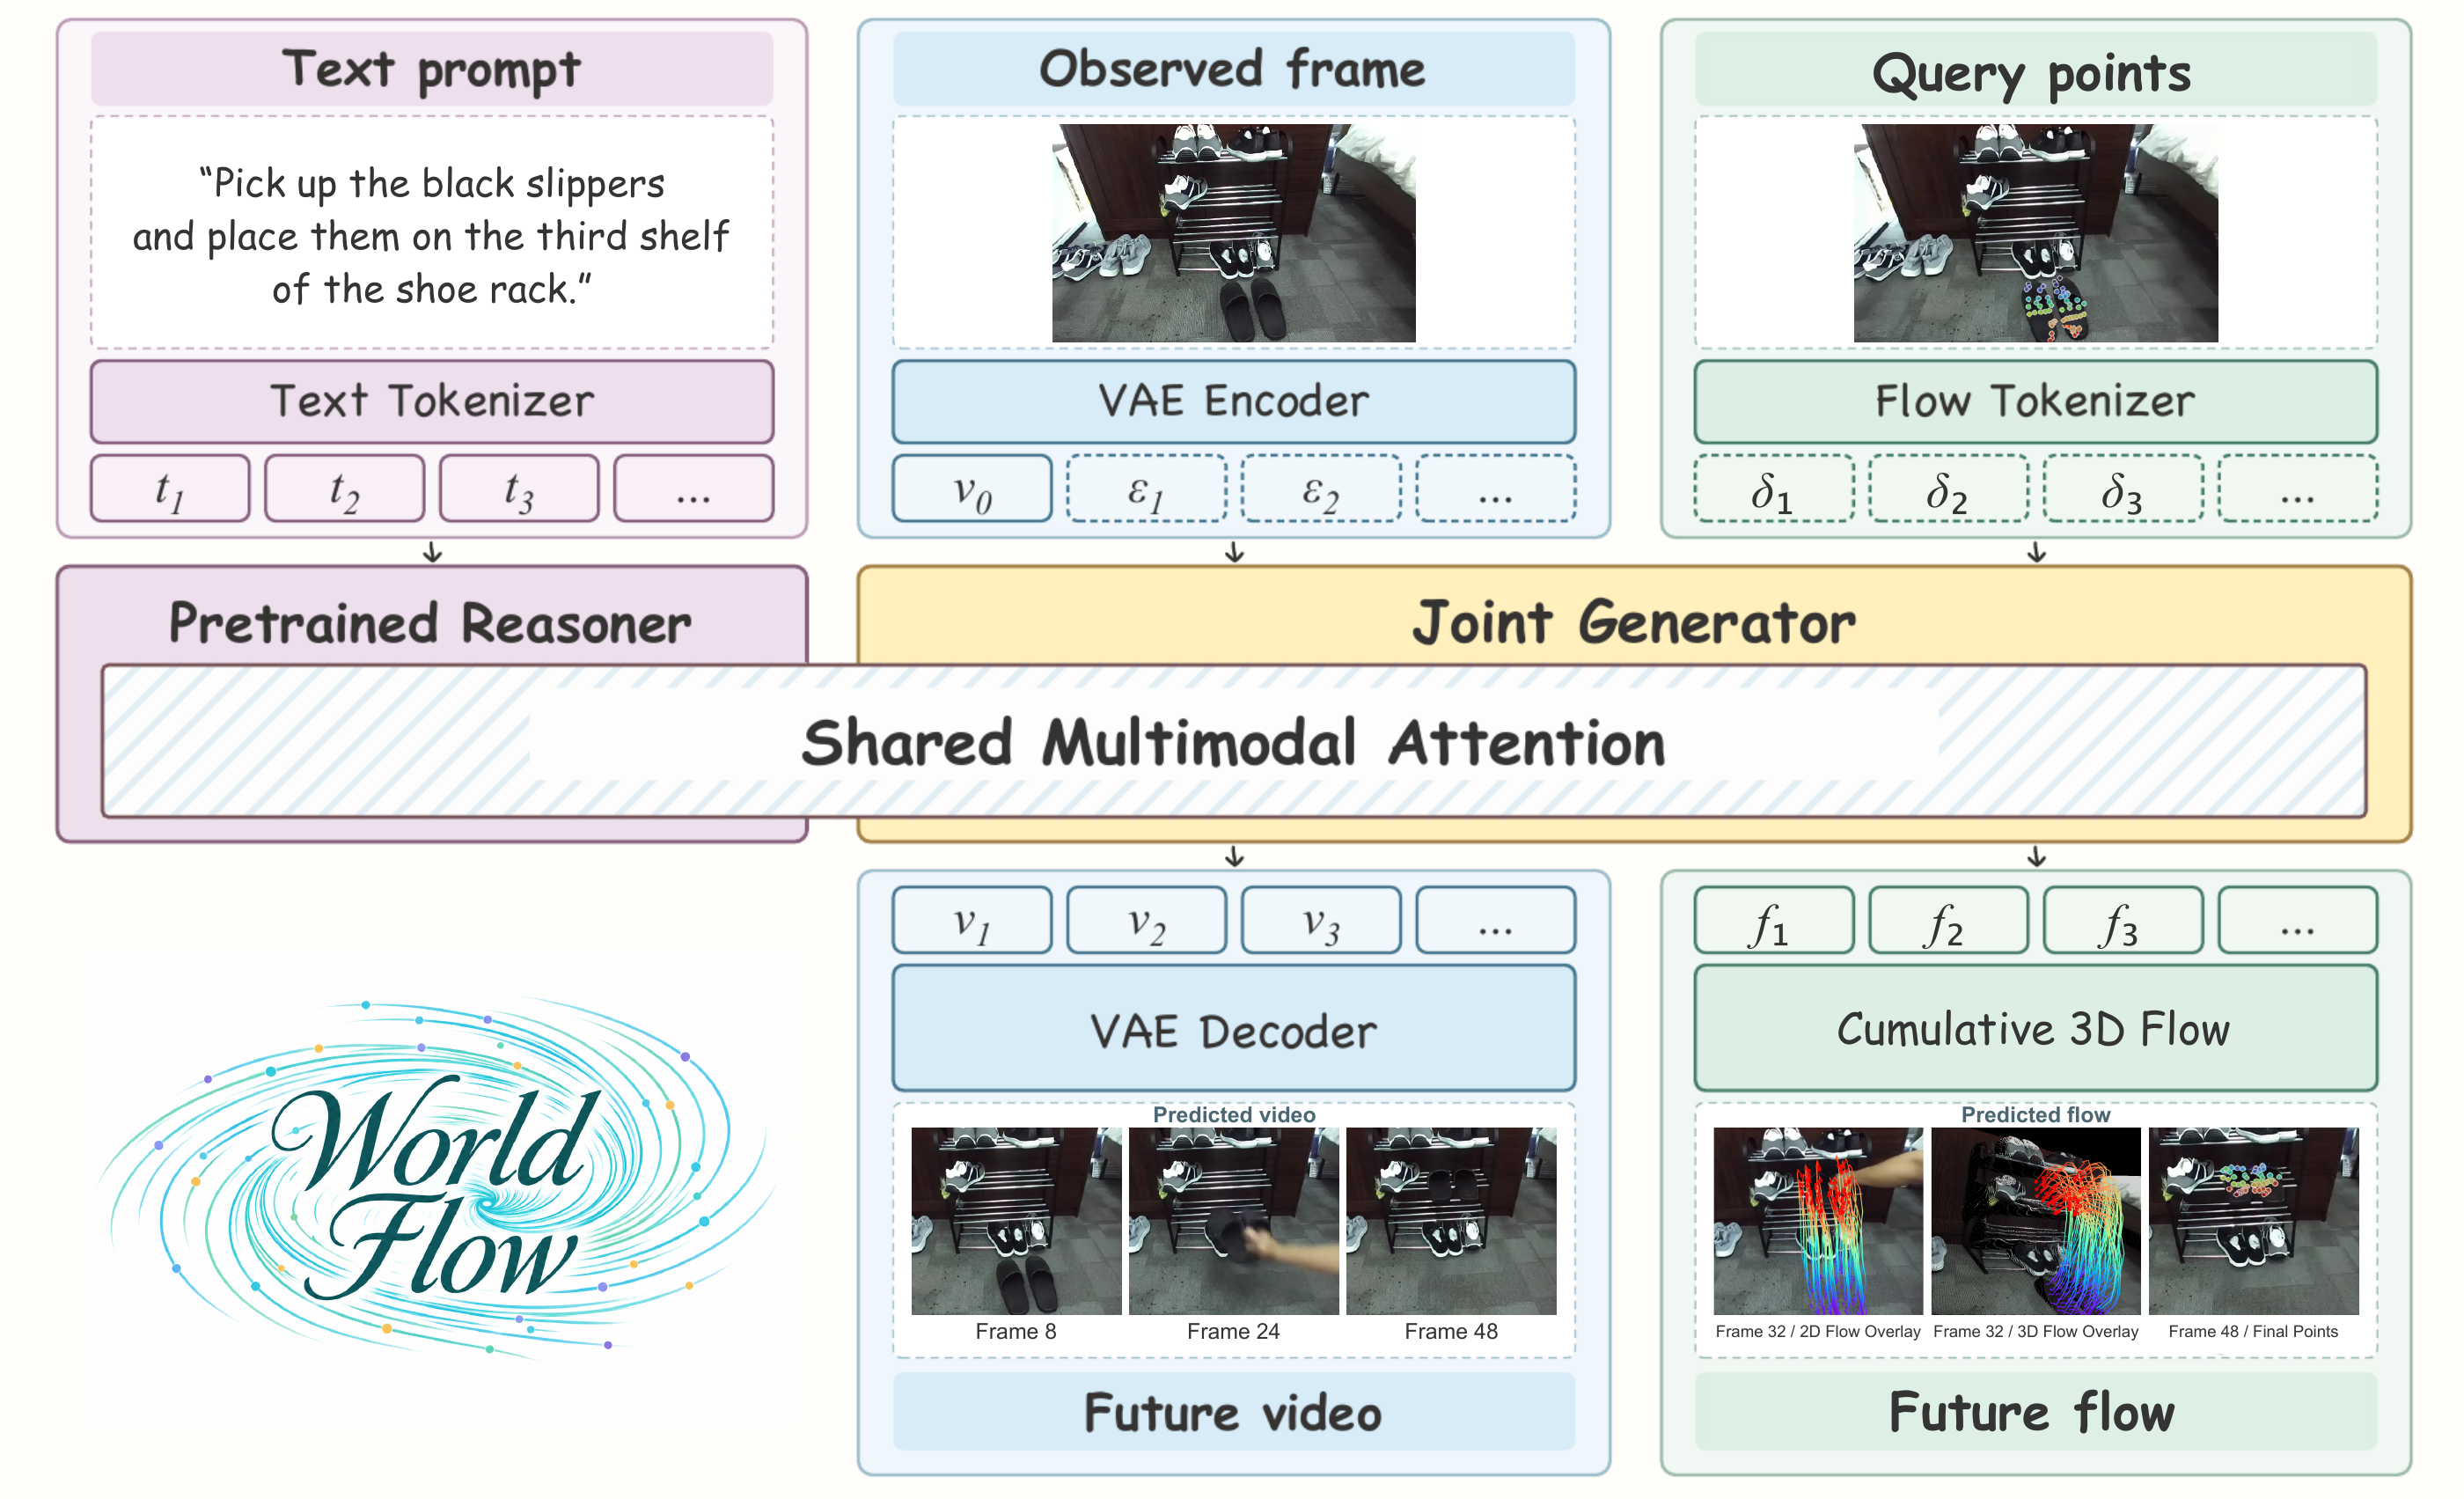
| Oct 29, 2026 | Introducing WorldFlow, our new work on joint video and 3D motion prediction, now available on arXiv. |
|---|---|
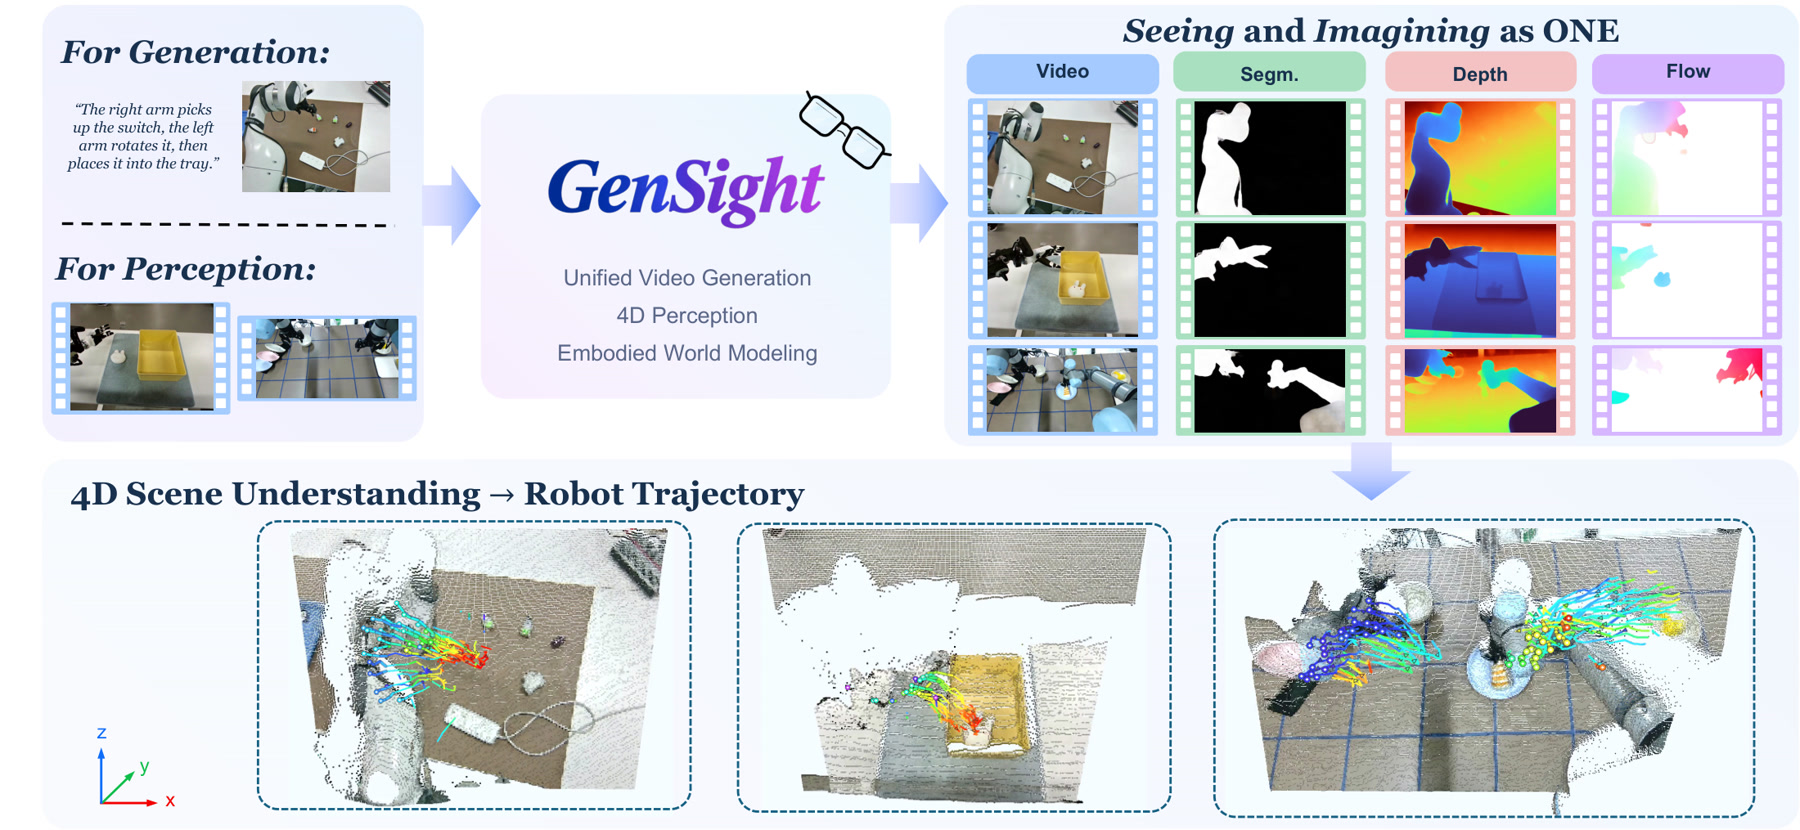
| Oct 29, 2026 | Our new work GenSight on unified video generation and 4D perception is now on arXiv! |
| Nov 01, 2025 | Led RoboScience’s World Model Group to develop embodied world models from the ground up. |
| Apr 01, 2025 | Started an internship (Apr–Oct 2025) at the World Model Group, Autonomous Driving Center, XPeng, working on world model RL post-training, mentored by Yu ZHANG. |
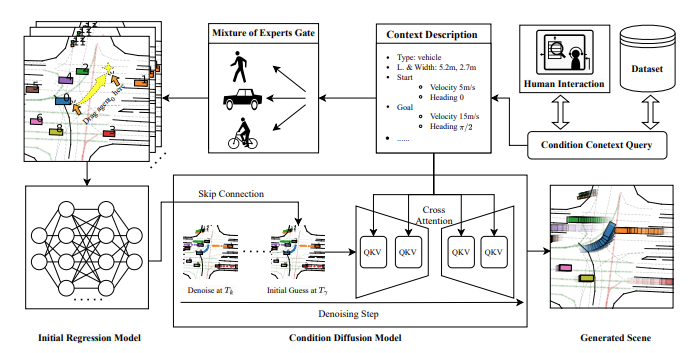
| Oct 15, 2024 | Invited to present DragTraffic on Interaction-aware Autonomous Systems workshop, hosted by Marcel Hallgarten. |